Skip to content

THE HARDWARE

The Ferret inspection robot

Co-designed with pipe operations service providers, the Ferret combines hands-free navigation, full HD 360° inspection footage and detailed 3D pipe data. A fully modular design supports fast maintenance and capability upgrades, helping your team take on demanding inspection work.

  • 360° HD footage
  • 3D reconstruction
  • 1 km live tether
  • Hot-swappable batteries
  • Fully modular design
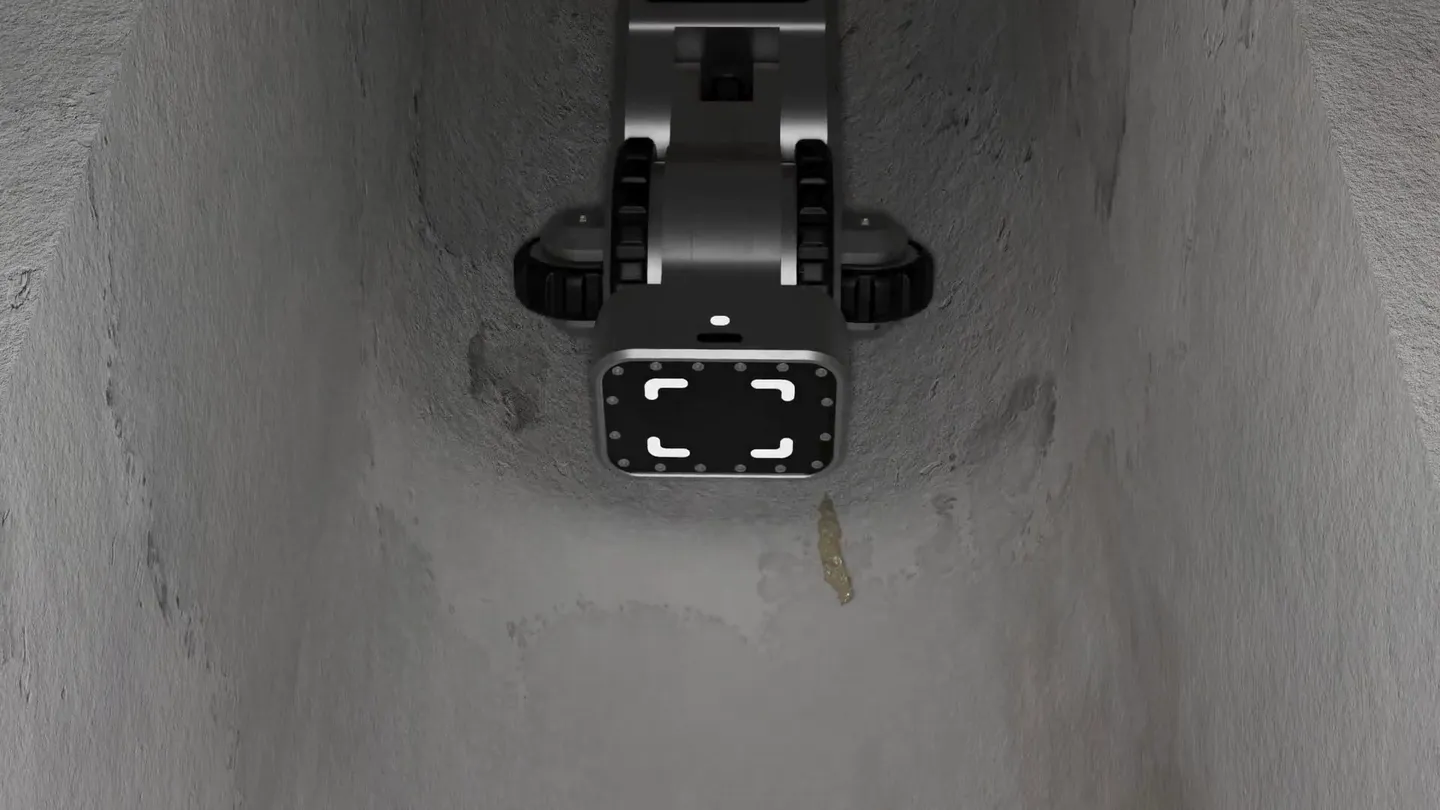
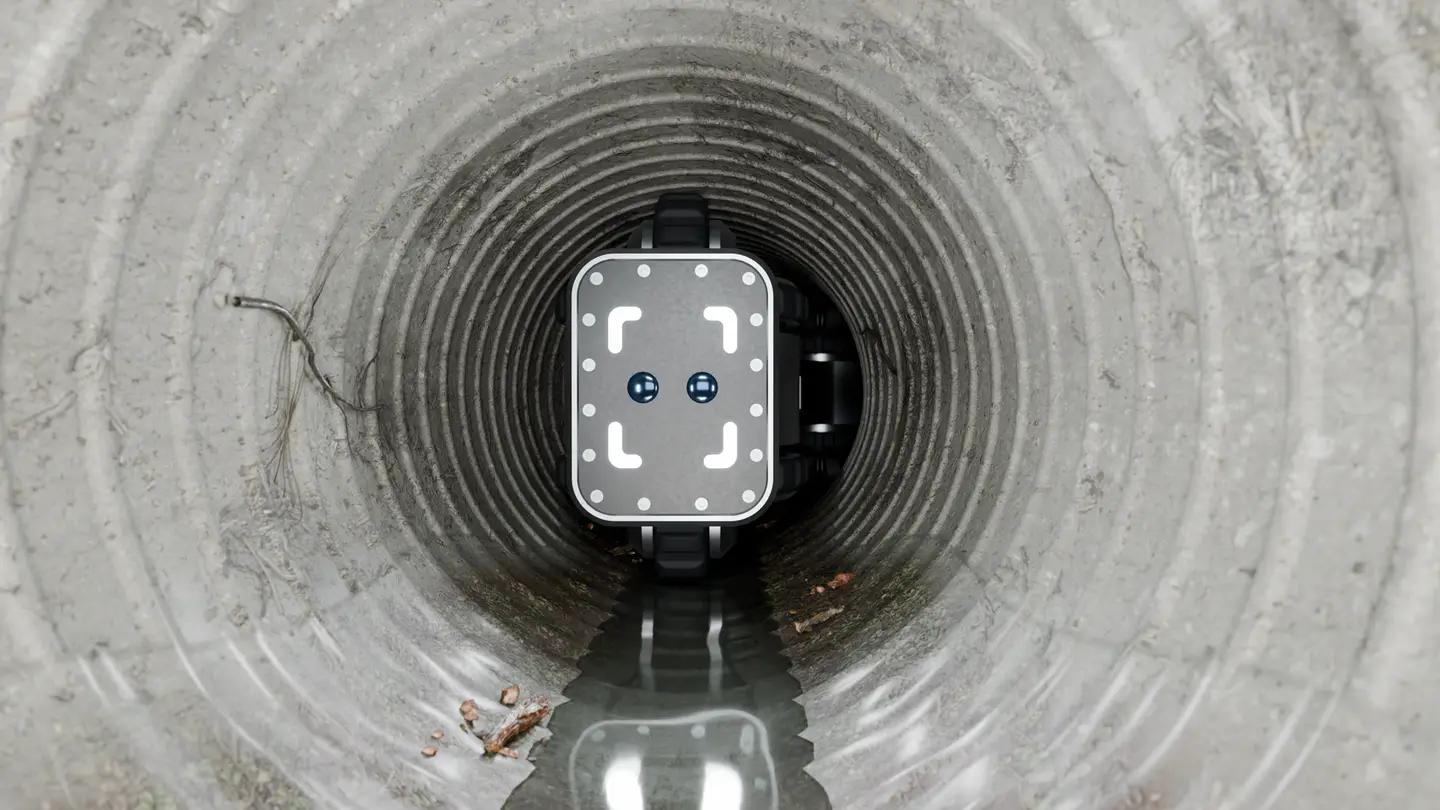
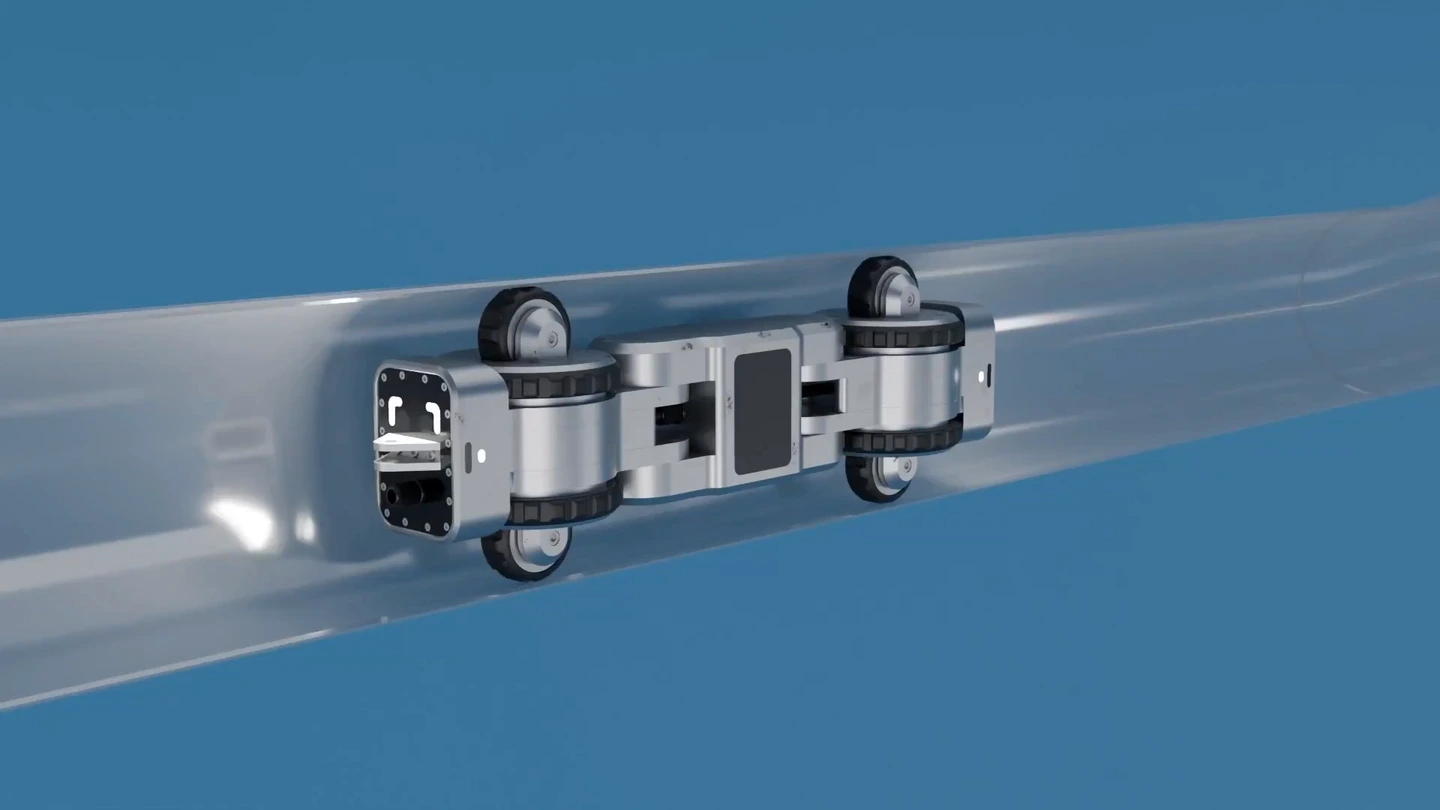
A rendered fly-around of the Ferret inside a cutaway pipe, its wheels braced against the pipe wall

Four capabilities. Built around your work.

Autonomy, navigation, data and modularity. Co-designed with industry to address how your crews inspect, assess and maintain their equipment.

PILLAR 01: AUTONOMY

The Ferret navigates. Your operator assesses.

Hands-free navigation lets your operator concentrate on pipe condition rather than steering through every metre of the inspection. Manage the Ferret from the base station, use the Grading Co-Pilot to support assessment and take manual control whenever needed. Live cloud sync connects the field inspection with PuralinkOS.

Operation
Hands-free pipe navigation
Assessment
Operator-led, Co-Pilot assisted
Control
Manual takeover when needed
Connection
Live cloud sync

PILLAR 02: NAVIGATION

Keep inspecting through complex pipework.

Traverse corners, intersections, vertical pipes, flow and damaged sections. The Ferret can even flip without stopping the inspection. Compression and crawler modes cover different pipe geometries, while manhole transitions let your crew continue between sections without retrieving and redeploying at every access point.

Traversal
Corners, intersections and vertical pipes
Conditions
Flow and damaged pipework
Continuity
Flip without stopping the inspection
Modes
Compression and crawler

PILLAR 03: DATA

Capture the detail your clients need.

Collect full HD 360° footage throughout the inspection, together with exact asset location, a dense point cloud and a photogrammetric reconstruction. Give your team and your clients visual and geometric information for condition assessment, structural analysis and ovality assessment.

Vision
Continuous full HD 360° footage
Location
Exact asset location
Geometry
Dense point cloud and photogrammetry
Application
Condition and structural assessment

PILLAR 04: MODULARITY

Maintain the robot. Expand its capability.

Every component of the Ferret can be swapped for fast maintenance. Replace the component that needs attention and upgrade to new capabilities as your inspection requirements evolve. Hot-swappable batteries, each providing 3+ hours of runtime, keep your crew working without waiting for a depleted battery to recharge.

Maintenance
Swappable components throughout
Upgrades
Add new capabilities through modules
Power
Hot-swappable batteries
Runtime
3+ hours per battery
01 / 04—Autonomy

SPECIFICATION

The capability behind the inspection

Inspection coverage, operating range and field specifications to help you assess the Ferret for your work.

360°
Full HD inspection footage
1 km
Tether for live communication
3+ hr
Runtime per hot-swappable battery
600 kg
Rated tether pull force for emergency retrieval
Vision
Full HD 360° footage throughout the inspection
3D data
Dense point cloud and photogrammetric reconstruction
Tether
1 km live communication; 600 kg rated pull force
Runtime
3+ hours per battery; hot-swappable
Compression mode
DN150–DN300 pipes · 6–12 inch
Crawler mode
DN150–DN1500 pipes
Modularity
All robot components swappable for maintenance and upgrades
Asset location
Exact asset location captured with inspection data

MODULARITY

Built to maintain. Designed to evolve.

Co-designed with service providers who need equipment back in the field. Swappable components support fast maintenance and make it easier to introduce new inspection capabilities.

01

Drive modules

Navigate corners, intersections, vertical pipes, flow and damaged sections with drive assemblies that form part of the fully modular robot.

02

Vision module

Capture full HD 360° footage throughout the inspection, giving your operator a view around the pipe rather than only in one direction.

03

3D reconstruction

Generate a dense point cloud and photogrammetric reconstruction for detailed assessment of pipe geometry, including ovality.

04

Capability upgrades

Introduce new capabilities through replaceable components, allowing the Ferret to evolve with your inspection requirements.

05

Battery module

Get 3+ hours of runtime from each hot-swappable battery. Replace a depleted battery and continue work without waiting for it to recharge.

06

Base station

Manage the Ferret, assess condition with the Grading Co-Pilot and take manual control when needed, with live sync to PuralinkOS.

IN THE PIPE

Two modes. One inspection robot.

Compression and crawler modes let your team inspect a broad range of pipe diameters and geometries with the Ferret.

Render · crawler mode
Crawler mode · DN150–DN1500 pipes
Render · compression mode
Compression mode · DN150–DN300 pipes

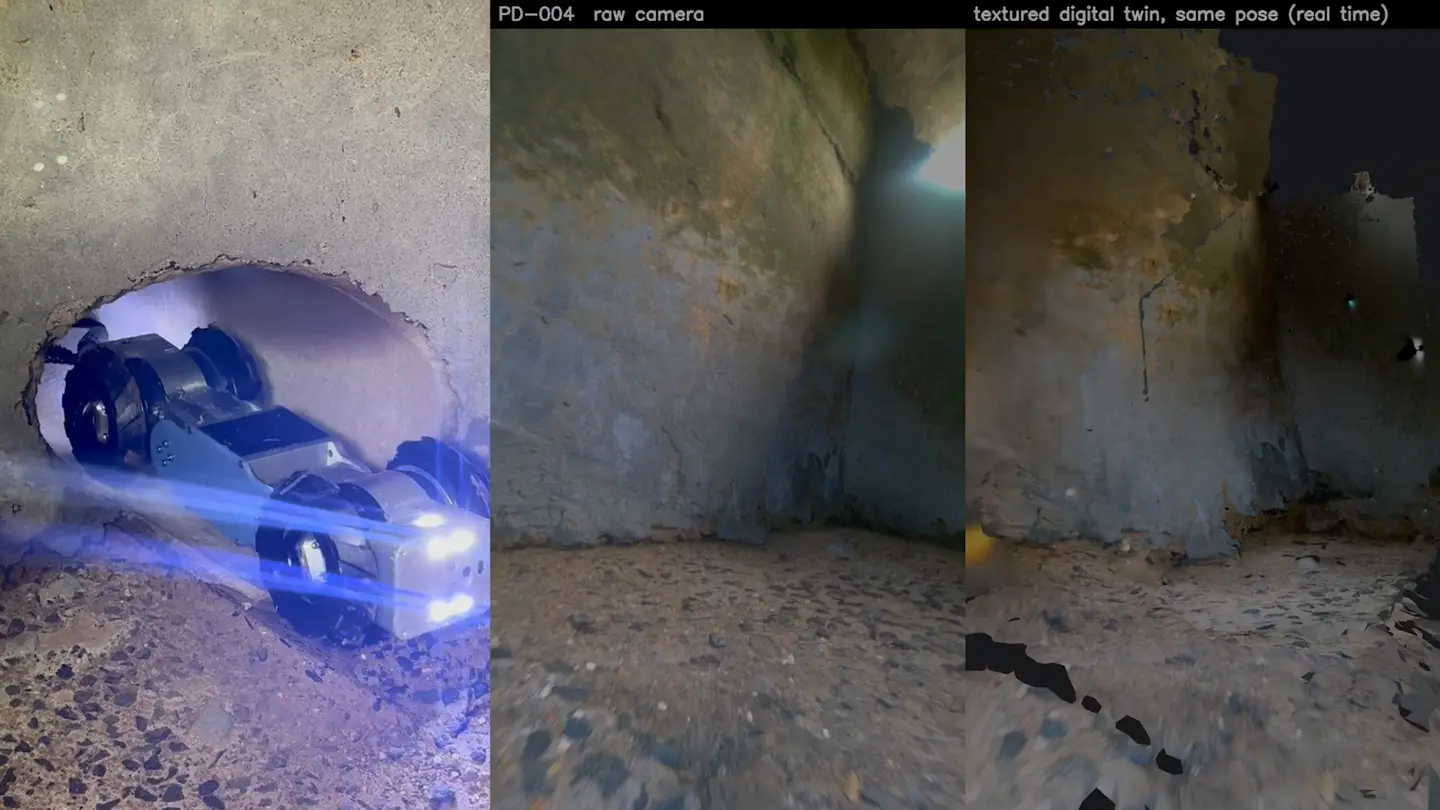
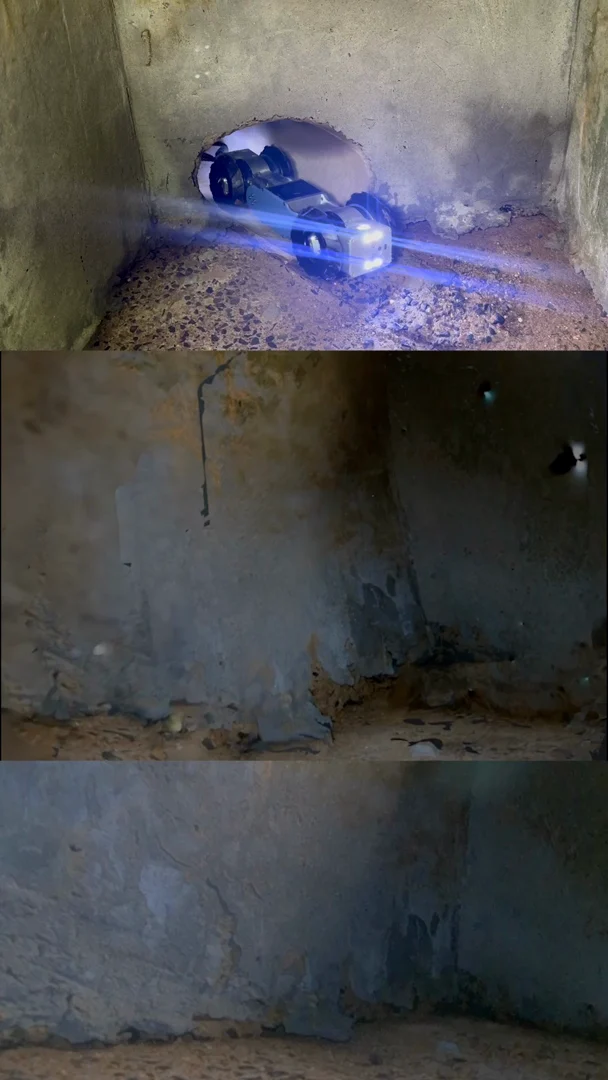
field footage

From the pipe interior to a detailed 3D reconstruction

faq

Ferret questions

The Ferret is Puralink's autonomous pipe inspection robot, co-designed with pipe operations service providers. It combines hands-free navigation with full HD 360° footage, exact asset location and detailed 3D pipe data. Its fully modular design supports fast maintenance and upgrades to new capabilities.

The Ferret operates in compression mode in DN150–DN300 pipes, equivalent to 6–12 inches, and crawler mode in DN150–DN1500 pipes. Share your pipe dimensions and configuration through the Get Started form so we can discuss your application.

Deployment is through an available access point, such as a manhole or entry chamber. The Ferret can also traverse manhole chambers to continue into adjoining pipe sections, reducing the need to retrieve and redeploy between sections. The deployment approach depends on the access and configuration of your asset.

The Ferret can navigate flowing pipes. Whether an inspection can proceed under operating conditions depends on the asset and the conditions of the job. Share the application and flow conditions with our team when submitting your expression of interest.

The Ferret has a 1 km tether for live communication. Achievable inspection distance depends on the pipe route, access and operating conditions. The tether has a 600 kg rated pull force for emergency retrieval peace of mind, and each hot-swappable battery provides 3+ hours of runtime.

Yes. The Ferret can traverse corners, intersections, vertical pipes, flow and damaged sections, and can flip without stopping the inspection. Hands-free navigation lets the operator focus on condition assessment, with manual takeover available when needed.